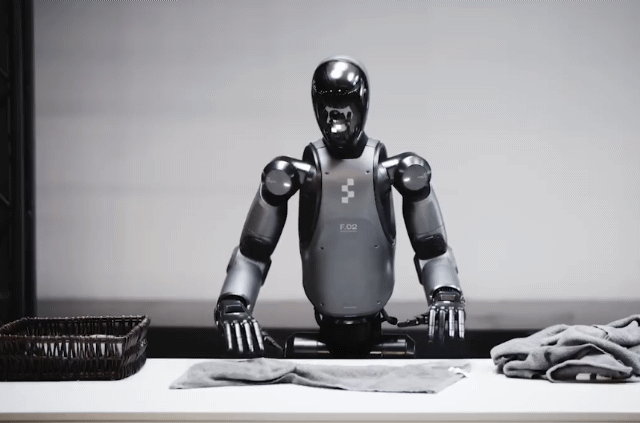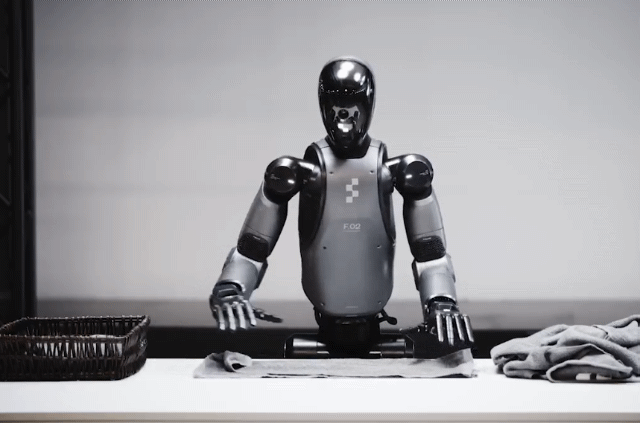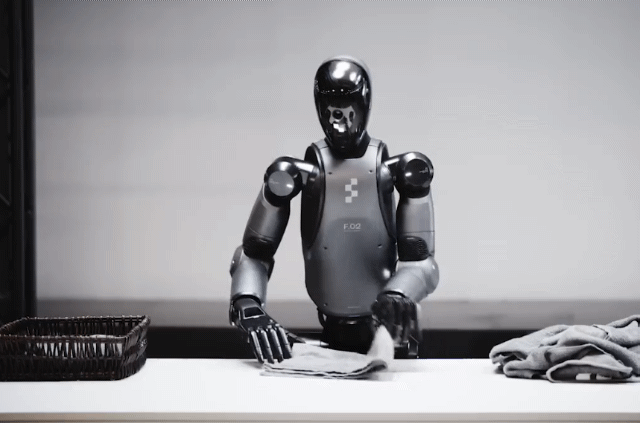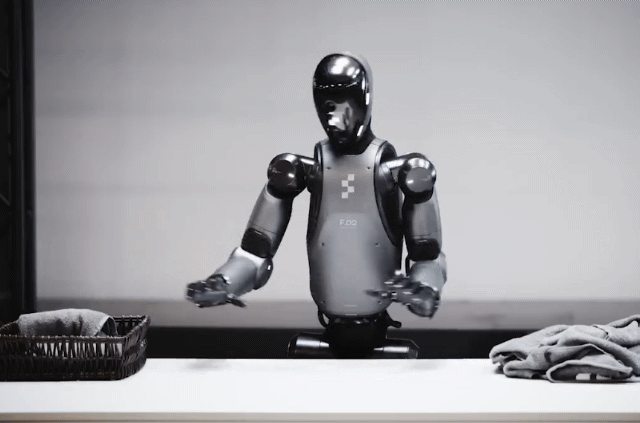
Humanoid Robot AI
Combine perception, locomotion, manipulation, and whole-body coordination for autonomous humanoids.
Whole-body controlManipulation & planning

PEARL explores physical AI and robotics for real-world autonomous systems.
Combine perception, locomotion, manipulation, and whole-body coordination for autonomous humanoids.
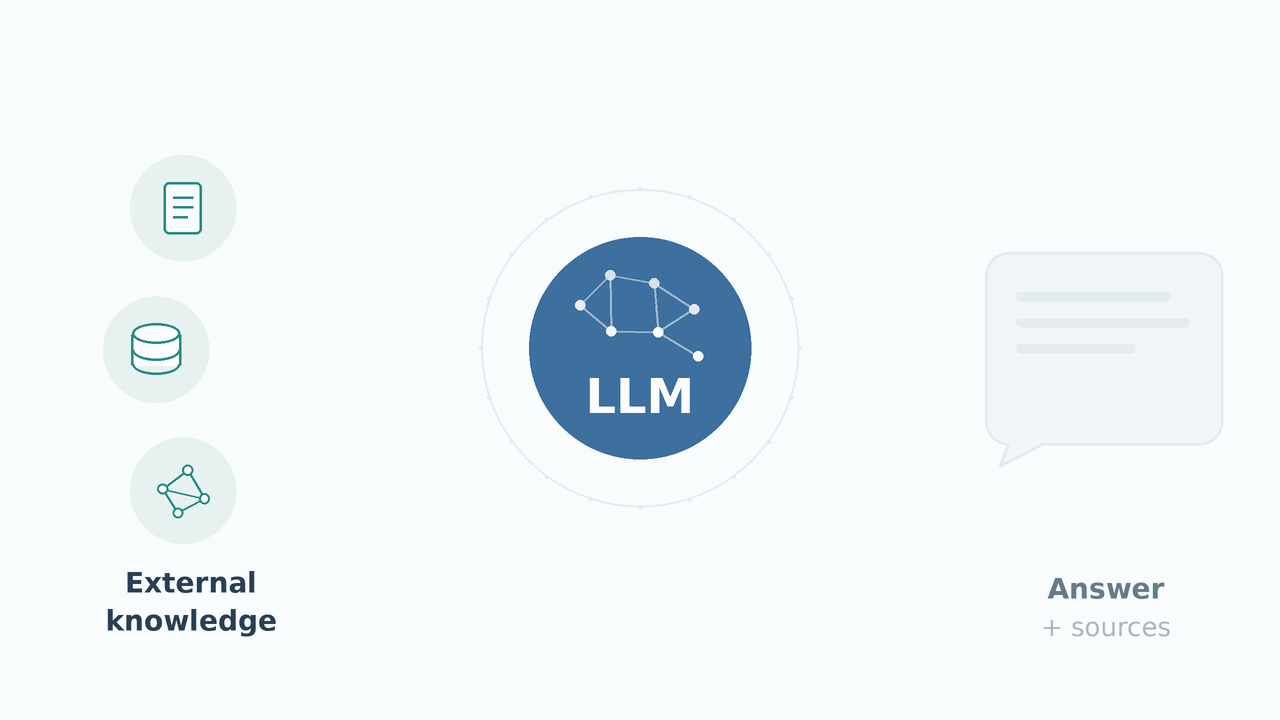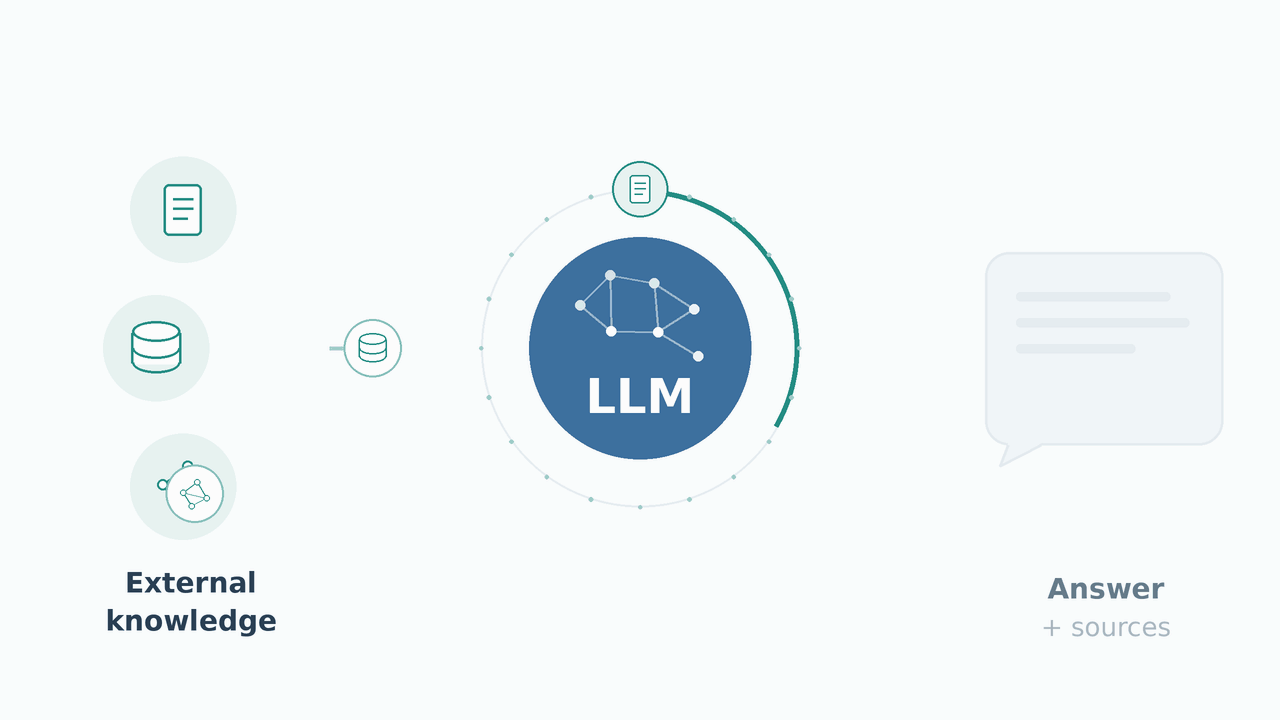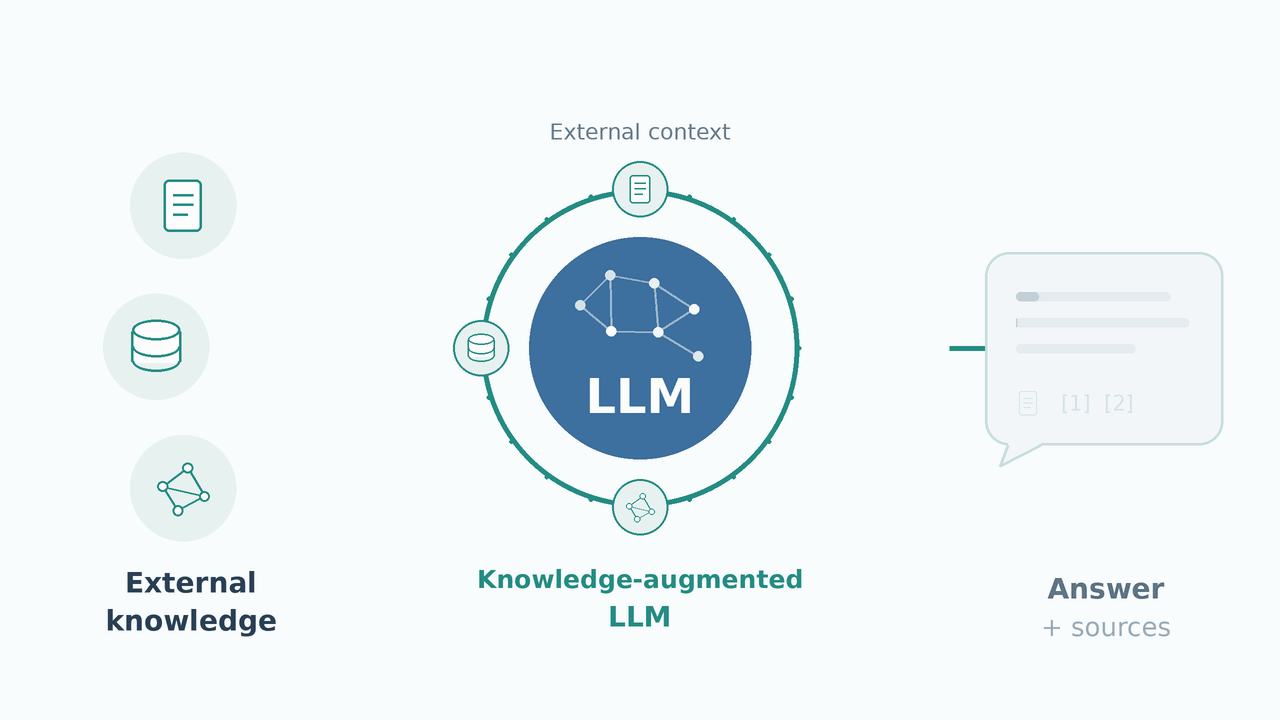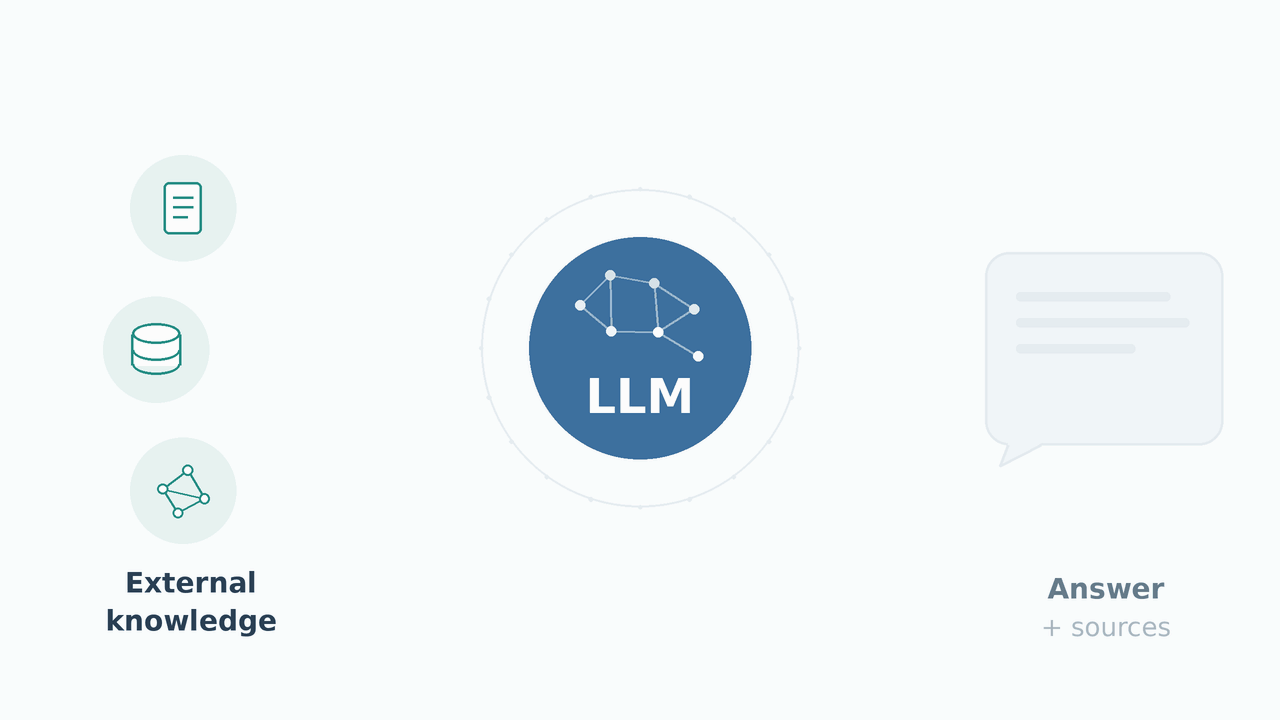
Retrieve relevant knowledge and connect it to generative models to produce grounded answers.
Study AI agents that maintain consistent personas and adapt their interactions to users and context.
Use vision and sensors to perceive changing surroundings, plan flight paths, and make autonomous decisions.
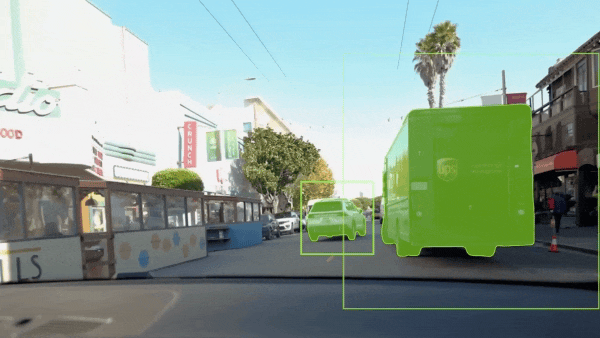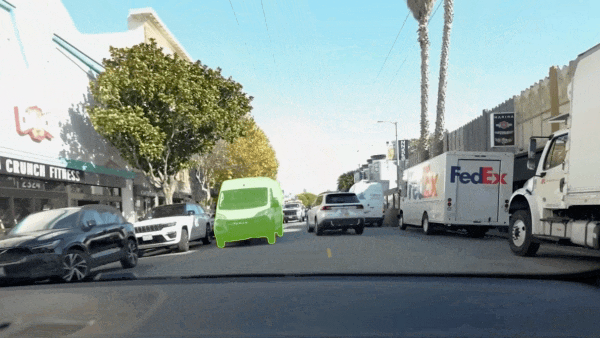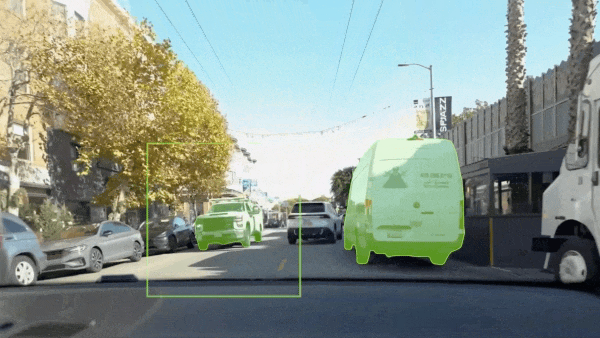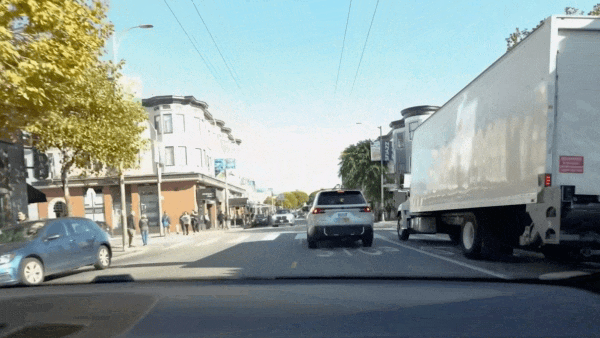
Develop perception, localization, and planning for autonomous driving in real-world traffic.
Study localization, detection, and navigation where visibility and communication are limited.
Enable unmanned surface vehicles to perceive waterways, plan routes, and coordinate with other robots.
Study perception, decision-making, and robust autonomy for robots in uncertain field environments.
All fields related to Physical AI, LLMs, and robots.